
AnyCalib: On-Manifold Learning for Model-Agnostic Single-View Camera Calibration AnyCalib is a model-agnostic method for calibrating camera intrinsic parameters from a single in-the-wild image. It bypasses the need for extrinsic cues and works across multiple camera models,
MACHINE LEARNING
-

RWKV-7 Goose: State-of-the-art Multilingual Language Model
By
–
RWKV-7 "Goose" with Expressive Dynamic State Evolution RWKV-7 "Goose" is a sequence modeling architecture that achieves state-of-the-art multilingual performance with 3 billion parameters. Despite training on fewer tokens than other top models, it excels in both English and
-

New Metric Measures AI Long-Task Completion Ability
By
–
Measuring AI Ability to Complete Long Tasks This paper introduces a new metric, the 50%-task-completion time horizon, to measure AI's ability to complete long tasks. It tracks the time it takes for AI models to match the 50% success rate in tasks that humans typically complete.
-
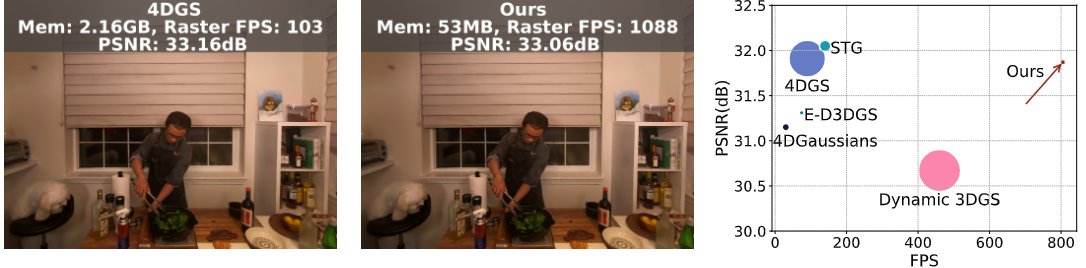
4DGS-1K Achieves 1000+ FPS Dynamic Scene Rendering Innovation
By
–
1000+ FPS 4D Gaussian Splatting for Dynamic Scene Rendering This paper presents 4DGS-1K, a faster and more memory-efficient framework for dynamic scene rendering, achieving over 1000 FPS on modern GPUs by improving 4D Gaussian Splatting (4DGS). Problem: 4DGS faces two
-
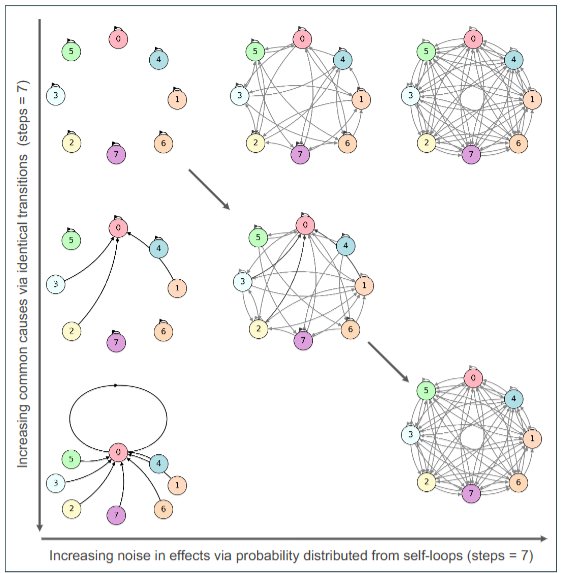
Causal Emergence 2.0: Quantifying Emergent Complexity
By
–
Causal Emergence 2.0: Quantifying emergent complexity This paper presents Causal Emergence 2.0 (CE 2.0), a theory that quantifies how different scales in complex systems contribute to causation and introduces a new measure of emergent complexity based on distributed causal
-
Top 10 Foundation Model Papers: Humanoid Robots and Multimodal LLMs
By
–
This week was huge for foundation models, from generalist humanoid robots to multimodal LLMs that learn from human preferences and negative examples – here are the top 10 papers for the week – DAPO: An Open-Source LLM Reinforcement Learning System at Scale
– GR00T N1: An -
Robotics for software engineers: AI and machine learning applications
By
–
Robotics for software engineers https://
buff.ly/4JTFJyV #AI #MachineLearning #DeepLearning #LLMs #DataScience -
Breadth is free, depth is expensive in neural network compute graphs
By
–
yep exactly, great work spelling it out step by step.
sometimes I talk about it as "breadth is free, depth is expensive" in the imagined full compute graph of the neural net. afaik this was the major insight / inspiration behind the Transformer in the first place. The first time -
Google’s 60X Larger Neural Network Achieved 70% ImageNet Error Reduction
By
–
We (Google) were already thinking along these lines prior to the Krizhevsky et al. work. Our work at ICML 2012 (
https://
arxiv.org/abs/1112.6209) trained a neural network that was 60X larger than prior neural nets, and improved ImageNet state-of-the-art by 70% relative error, using the -

Share AI and Machine Learning Insights with Your Network
By
–
If you found it insightful, reshare with your network. Find me → @akshay_pachaar For more insights and tutorials on AI and Machine Learning!