Source: forbes.com/sites/karlfreund/2026/04/06/did-amd-just-beat-nvidia-in-ai-performance/ [Translated from EN to English]
→ View original post on X — @kimmonismus, 2026-04-07 18:17 UTC
By
–
Source: forbes.com/sites/karlfreund/2026/04/06/did-amd-just-beat-nvidia-in-ai-performance/ [Translated from EN to English]
→ View original post on X — @kimmonismus, 2026-04-07 18:17 UTC
By
–

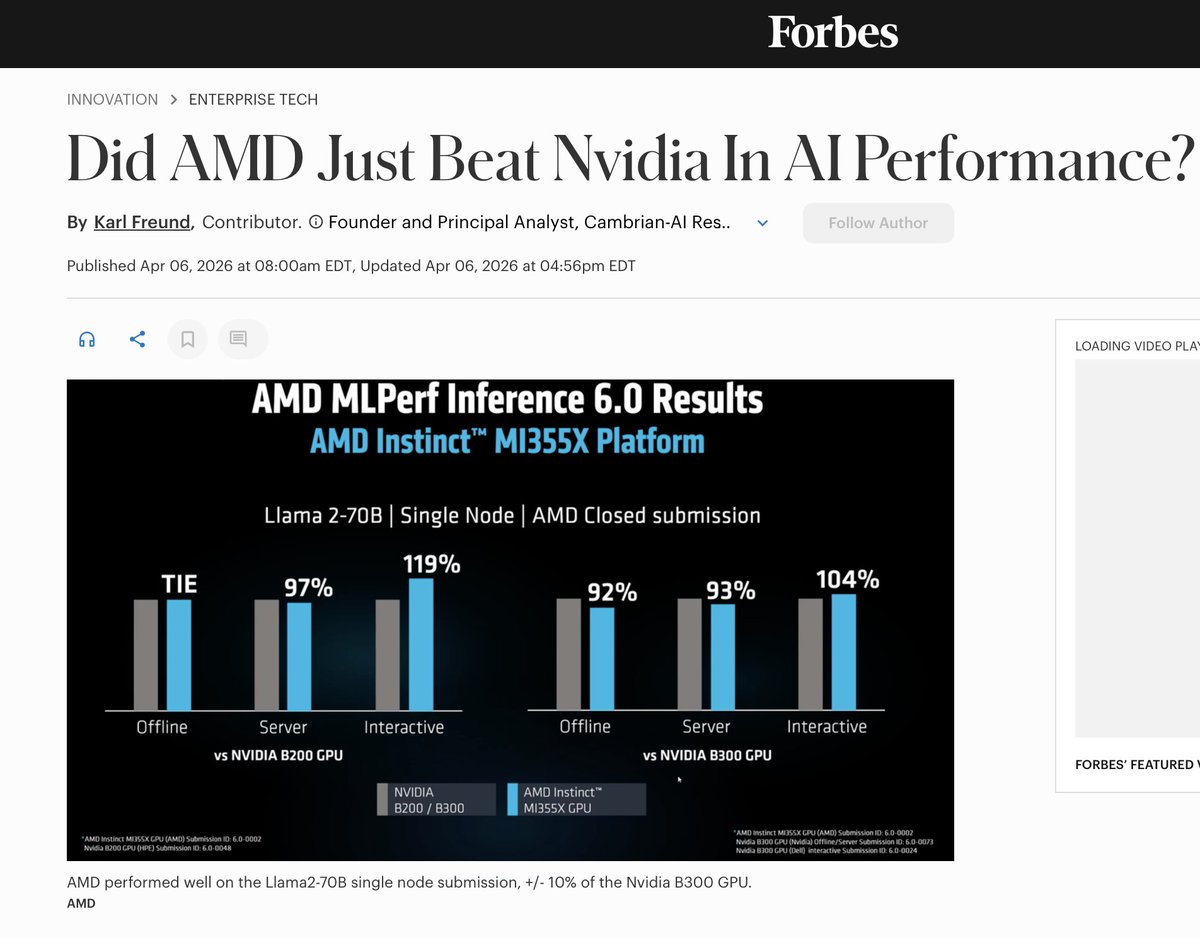
Did AMD Just Beat NVIDIA In AI Performance? No. And the article itself says so. I really don't like clickbaity headlines. They even state it at the very end, though the title suggest a bit otherwise: "NVIDIA ran every newly added benchmark and won every one of them. Only two of these were attempted by AMD, and for which Nvidia out-performed them by ~30 and ~50%. So, no, AMD did not beat Nvidia." MLPerf 6.0 results are out and the actual data tells a clear story: -NVIDIA won every new benchmark it entered -GB300 NVL72 delivered nearly 3x more throughput than 6 months ago, same hardware, better software -2.5M tokens/sec on DeepSeek R1 with 288 B300s AMD made real progress with the MI355X; getting within 10-30% on select single-node tests is no joke. And they deserve credits for that. But they skipped most new benchmarks and didn't compete on the hardest models. Imho / take: The real story isn't GPU vs GPU anymore. It's full-stack AI infrastructure: networking, software optimization, disaggregated serving. And tbh that's where NVIDIA keeps pulling ahead.
→ View original post on X — @kimmonismus, 2026-04-07 18:17 UTC
By
–
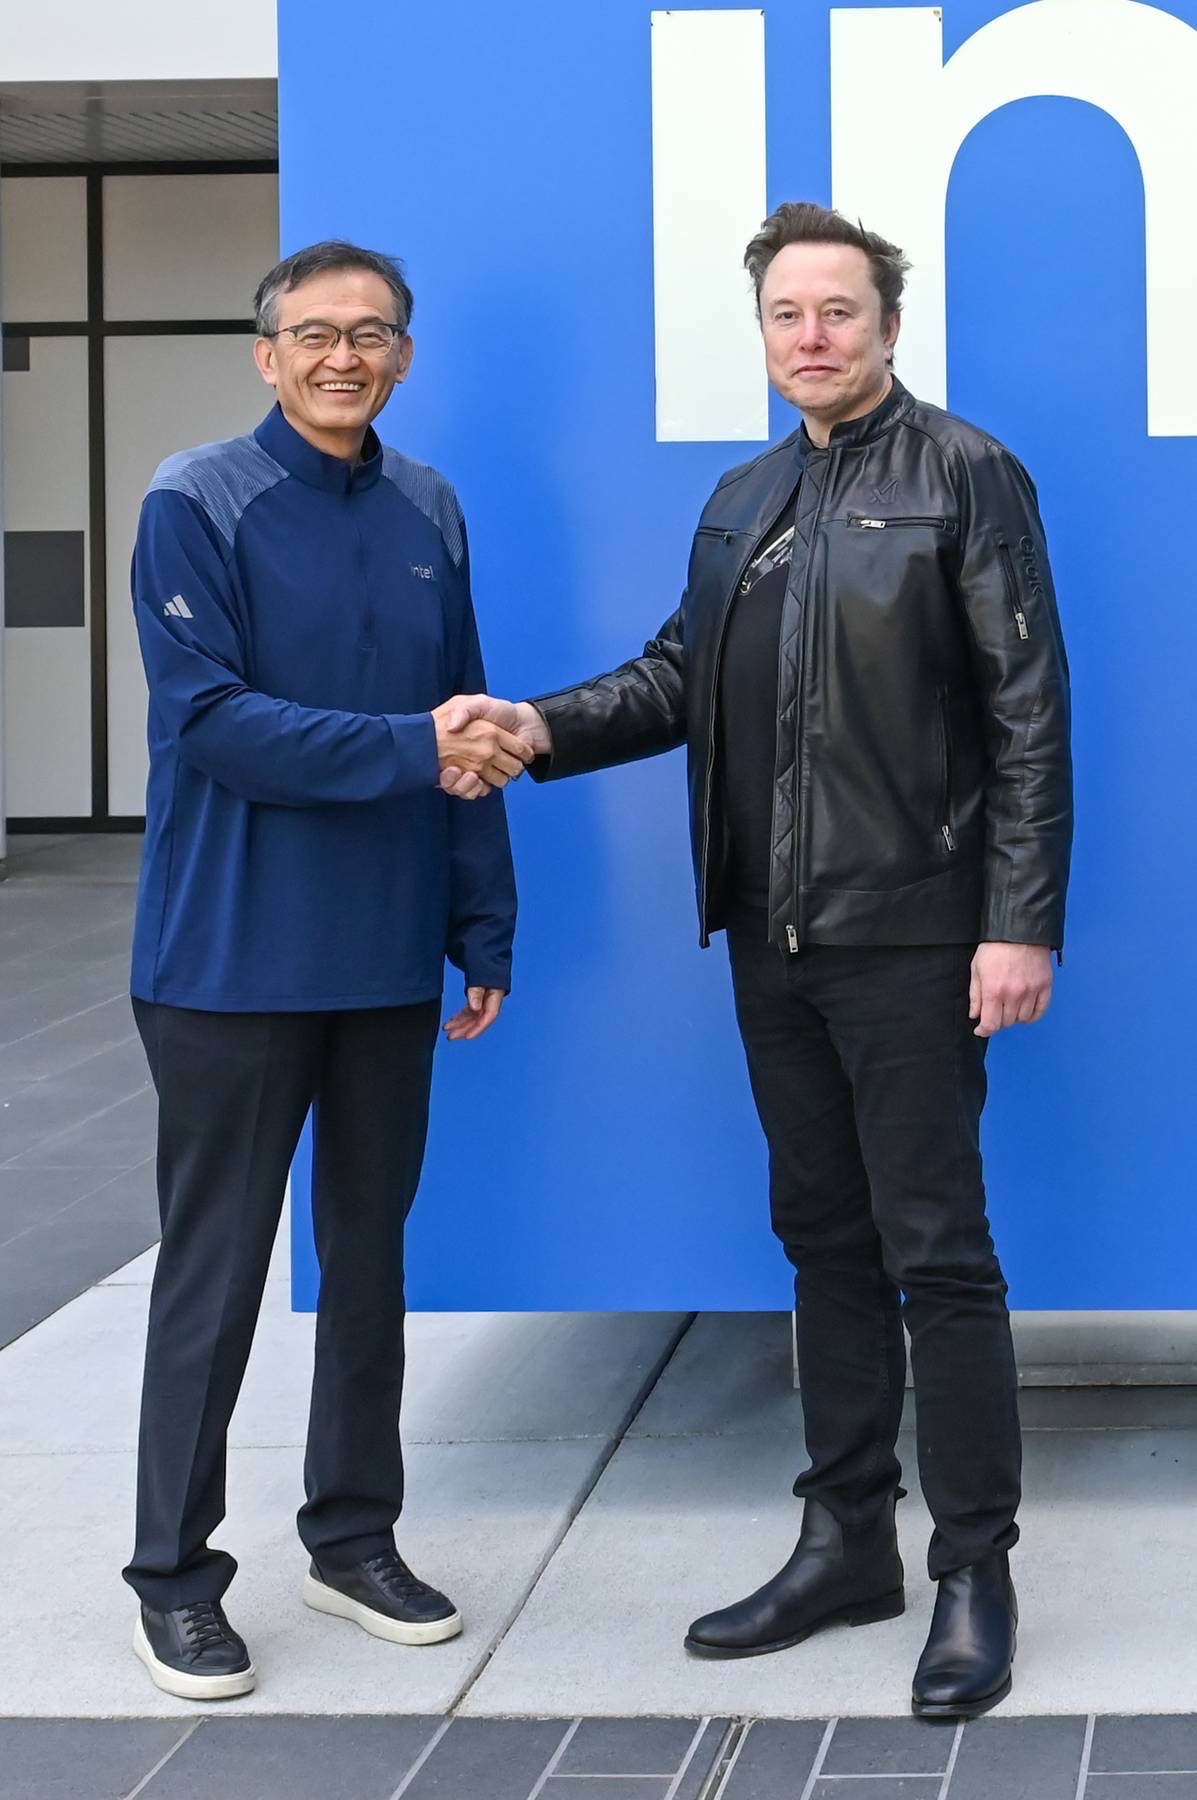
Honored to work with Intel and Lip-Bu
By
–
Looking forward to working with Intel on the Terafab!
By
–
Gravity-Defying #Robotic #Warehouse System: Ceiling- and Wall-Climbing #Automation
— Ronald van Loon (@Ronald_vanLoon) 7 avril 2026
via @ZappyZappy7
#Robot #MachineLearning #ArtificialIntelligence #ML pic.twitter.com/ks5DdvJcWX
Gravity-Defying #Robotic #Warehouse System: Ceiling- and Wall-Climbing #Automation via @ZappyZappy7 #Robot #MachineLearning #ArtificialIntelligence #ML
→ View original post on X — @ronald_vanloon, 2026-04-07 16:25 UTC
By
–
The VIBO sensor preprocesses vibration measurements locally with 20 kHz bandwidth, then transmits processed data over standard Modbus protocol.
By
–
Android XR is getting even better! 🥽✨ We’re rolling out 5 new features to deepen your immersion from auto-spatialization updates to community-requested refinements. 🧵Check out the thread below for some highlights:
→ View original post on X — @scobleizer, 2026-04-07 16:15 UTC
By
–
Wired MEMS vibration sensor sits on the hot, noisy equipment. Wireless gateway sits up to 10 meters away in a controlled zone.
— Lucian Fogoros (@fogoros) 7 avril 2026
Two-stage architecture: accuracy where it matters, cloud connectivity where it works.
Partner content with Tronics Microsystems. #tronics_ai pic.twitter.com/6MgWCnh0e1
Wired MEMS vibration sensor sits on the hot, noisy equipment. Wireless gateway sits up to 10 meters away in a controlled zone. Two-stage architecture: accuracy where it matters, cloud connectivity where it works.
Partner content with Tronics Microsystems. #tronics_ai
By
–
🔥 JUST IN:
— Lukas Ziegler (@lukas_m_ziegler) 7 avril 2026
Open-source robotics dataset from 100% real-world scenarios! 🤯
Chinese robotics company @AGIBOTofficial just released AGIBOT WORLD 2026, an open-source dataset systematically covering key embodied AI research directions.
Built entirely from real-world… pic.twitter.com/aADoukKKiO
🔥 JUST IN: Open-source robotics dataset from 100% real-world scenarios! 🤯 Chinese robotics company @AGIBOTofficial just released AGIBOT WORLD 2026, an open-source dataset systematically covering key embodied AI research directions. Built entirely from real-world environments: commercial spaces, and homes. Collected using AGIBOT G2 robots in free-form collection mode, providing structured, accurately annotated, high-quality data. Digital twin technology creates 1:1 scale replicas in simulation matching the real environments. Both real-world and simulation data are open-sourced. The AGIBOT G2 platform collects multiple data types simultaneously: RGB(D) cameras, tactile sensors, force sensors, LiDAR, IMU, and full-body joint states. Whole-body control coordinates arms, waist, and hands for complex tasks. First-person teleoperation lets operators control the robot from its perspective. The tasks covered are fine-grained manipulation, ultra-long-horizon tasks, spatial navigation, dual-arm coordination, and multi-agent/human-robot collaboration. The dataset includes error-recovery trajectories with annotations. Most datasets only show successful demonstrations. AGIBOT includes failures and how the robot recovers, teaching models how to handle mistakes. After collection, data is tested through policy training and real-robot deployment to ensure quality. Then processed through industrial quality control with multiple screening and cleaning rounds. Making it open-source accelerates embodied AI research by giving researchers access to high-quality real-world robot data at scale. 🇨🇳 Learn more here: agibot-world.com/ ~~ ♻️ Join the weekly robotics newsletter, and never miss any news → ziegler.substack.com
→ View original post on X — @clementdelangue, 2026-04-07 13:30 UTC