Very insightful points on the Sim2Real gap for manipulation vs locomotion.
MACHINE LEARNING
-
End of Era: Key AI Ecosystem Figure Steps Down
By
–
WHAT?? end of an era!! thank you for all that you’ve done for the ecosystem! Looking forward to what you do next Awni 🙂
-
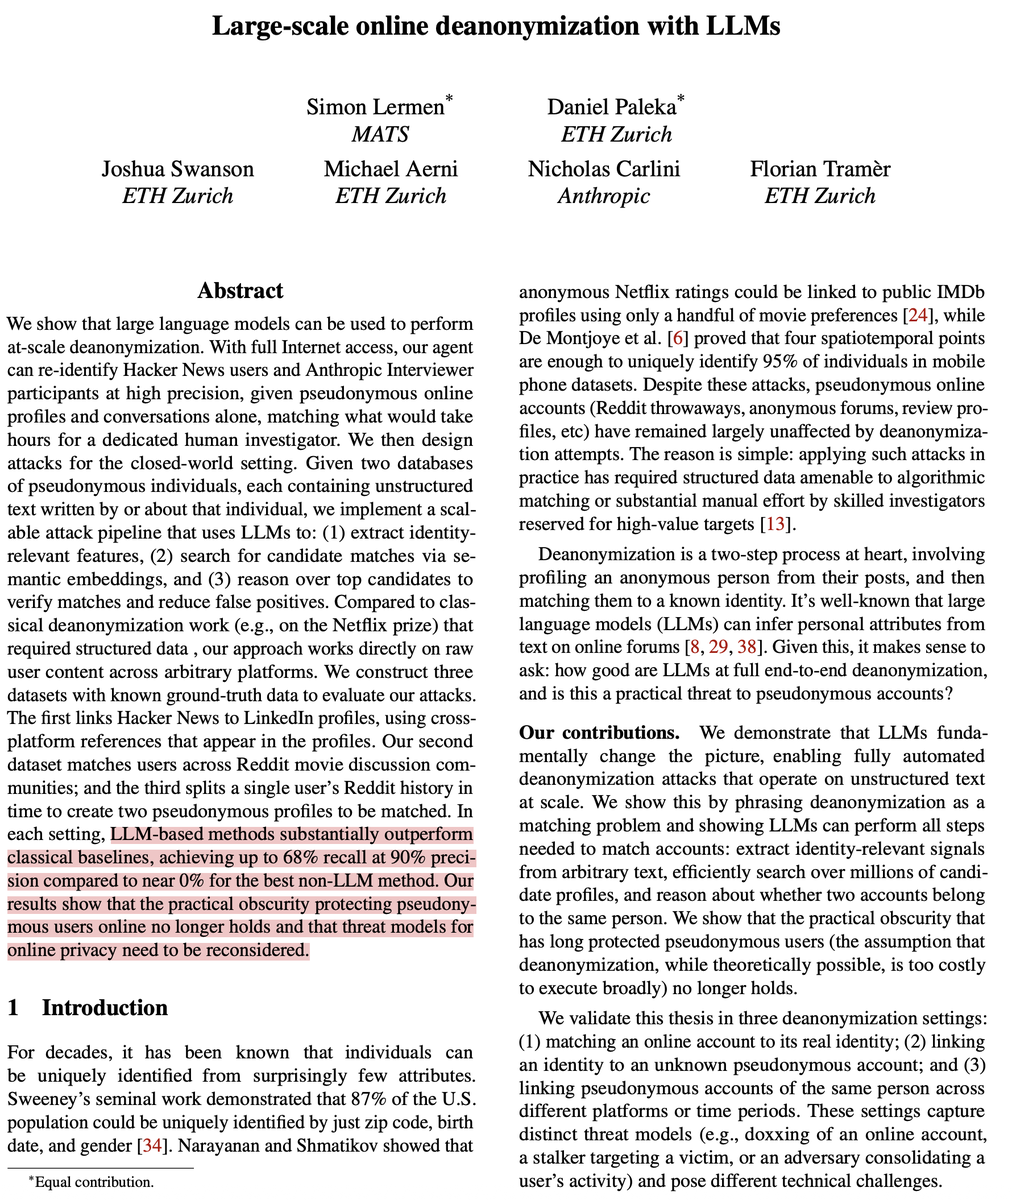
LLM De-anonymization: Why Routing Anonymity Alone Won’t Protect Privacy
By
–

Much talk about increasing privacy by creating a layer of anonymity routing between user & AI model provider. But what I truly don't get is this: commodity LLMs are already exceptionally good at identifying patterns & de-anonymizing. Why should we think they aren't capable of quickly relinking us? I'd wager that 1-shot re-identification by a model is easily possible across single prompts from multiple accounts, even if they are 'anonymously' routed to the API. Almost certainly especially true when users are working on the same bit of code, project, or from the same environment. Upshot: sort of like using Tor browser thinking you're anonymous from websites, but keeping cookies across sessions. The amount of muckery you'd have to do to context to be truly hardened against relinking by large models seems truly substantial to the point of massive inefficency. John Scott-Railton (@jsrailton) A lot of privacy has turned out to be just friction… …thats quickly being automated away. E.g. random anons could rest easy knowing manually de-anonymizing them wasn't worth the cost to anybody. Not true anymore. Now it's fast & scalable, especially for governments. — https://nitter.net/jsrailton/status/2027196811736485982#m
→ View original post on X — @mer__edith, 2026-02-27 21:39 UTC
-
World Models Accelerate Robot Policy Development via Simulation
By
–
Testing robot policies on hardware is slow, expensive and hard to scale. World models offer a promising path to accelerating robot policy development.
— Runway (@runwayml) 27 février 2026
We're sharing new research from the Runway Robotics team, in which we simulated 8 robot policies inside our General World Model… pic.twitter.com/169xGHIbFITesting robot policies on hardware is slow, expensive and hard to scale. World models offer a promising path to accelerating robot policy development. We're sharing new research from the Runway Robotics team, in which we simulated 8 robot policies inside our General World Model
-
WordPress Categories for AI-Related Content
By
–
Several people have asked me for a link, so here it is:
-
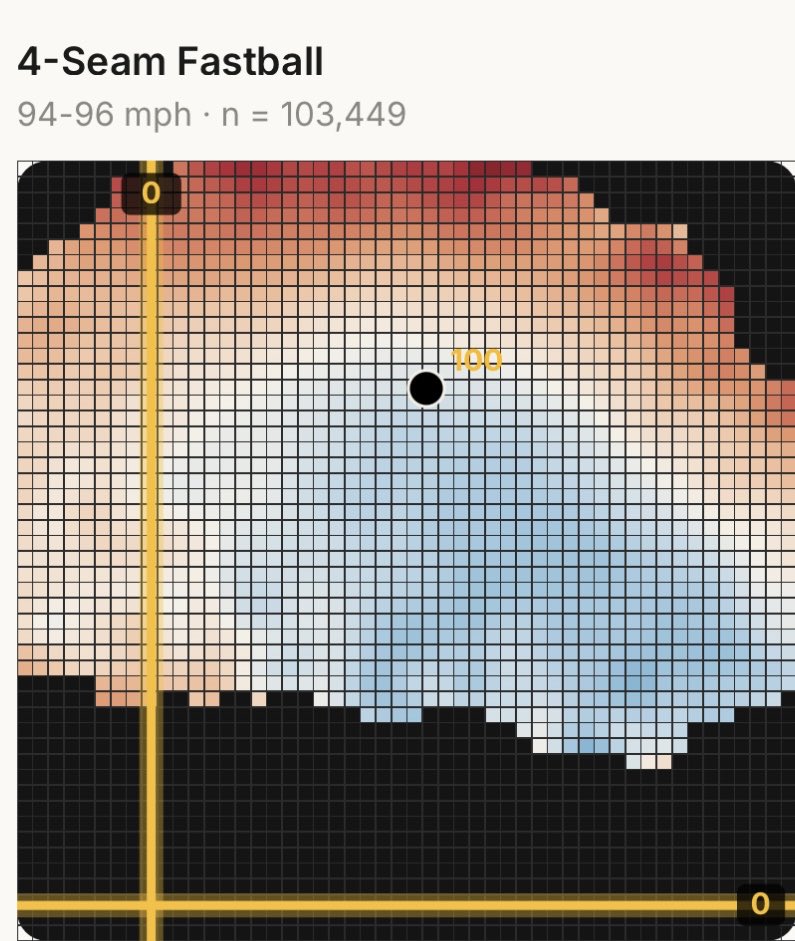
Baseball Player Builds ML Pitching Analytics Platform with AI
By
–
I’m a baseball player. I’ve never written a single line of code in my life. But over the last few months, I used AI to build a pitching analytics platform from scratch. 8.9M pitches. Custom ML models. Total transparency. Here is a look at what happens when you give an
-

Physics-Aware Image Editing with Latent Transition Priors
By
–
From Statics to Dynamics Physics-Aware Image Editing with Latent Transition Priors paper: https://
huggingface.co/papers/2602.21
778
… -
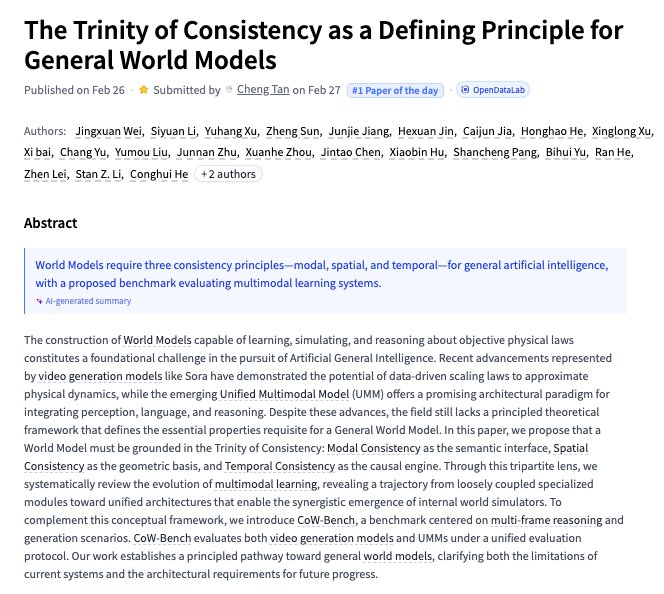
Trinity of Consistency: Defining Principle for General World Models
By
–
The Trinity of Consistency as a Defining Principle for General World Models paper: https://
huggingface.co/papers/2602.23
152
… -
Kaggle Model Stacking Trick for Machine Learning
By
–
Oh I see, the old Kaggle model stacking trick.
-
Weekly Dose of Optimism: Good News in AI and Tech
By
–
Read All the Good News That's Fit to Print in this week's Weekly Dose of Optimism from @notboringco